Robot Fleet Manager
Running
One operator panel for the fleet, and a Jetson Nano on each robot running the Robot Agent.
- lines of Python
- 2,008fleet server
- lines of Python
- 2,941Robot Agent + Alfa
- third-party packages
- 0standard library only
- offline sites
- 10OpenStreetMap
Robot Fleet Manager in short
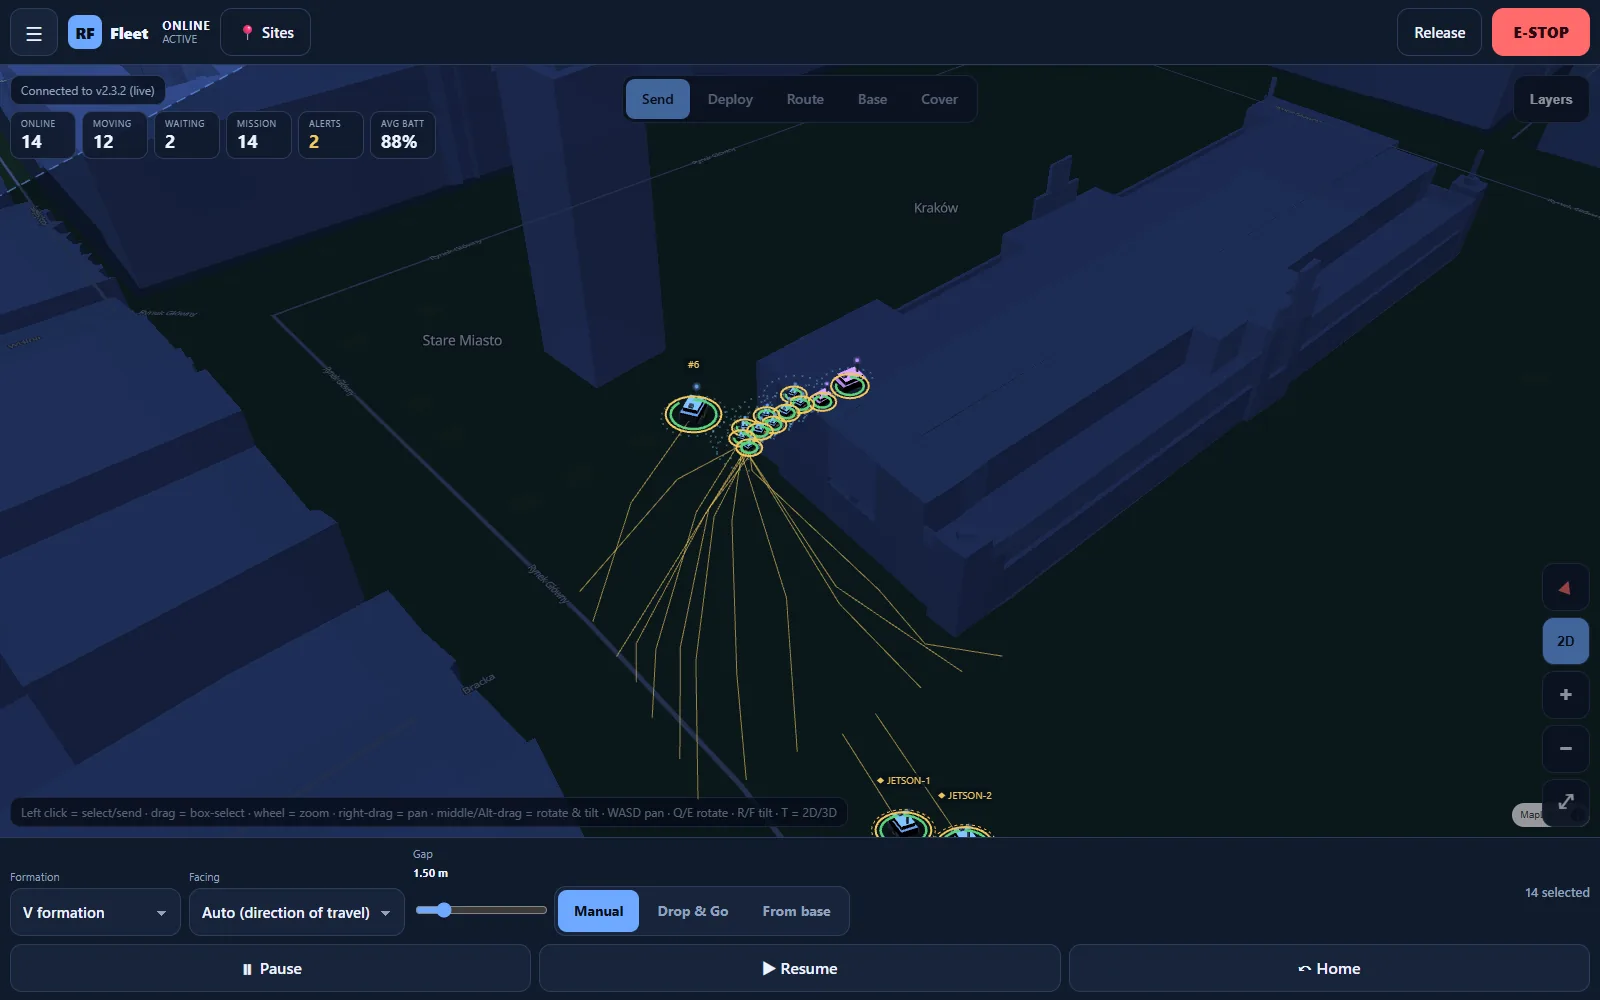
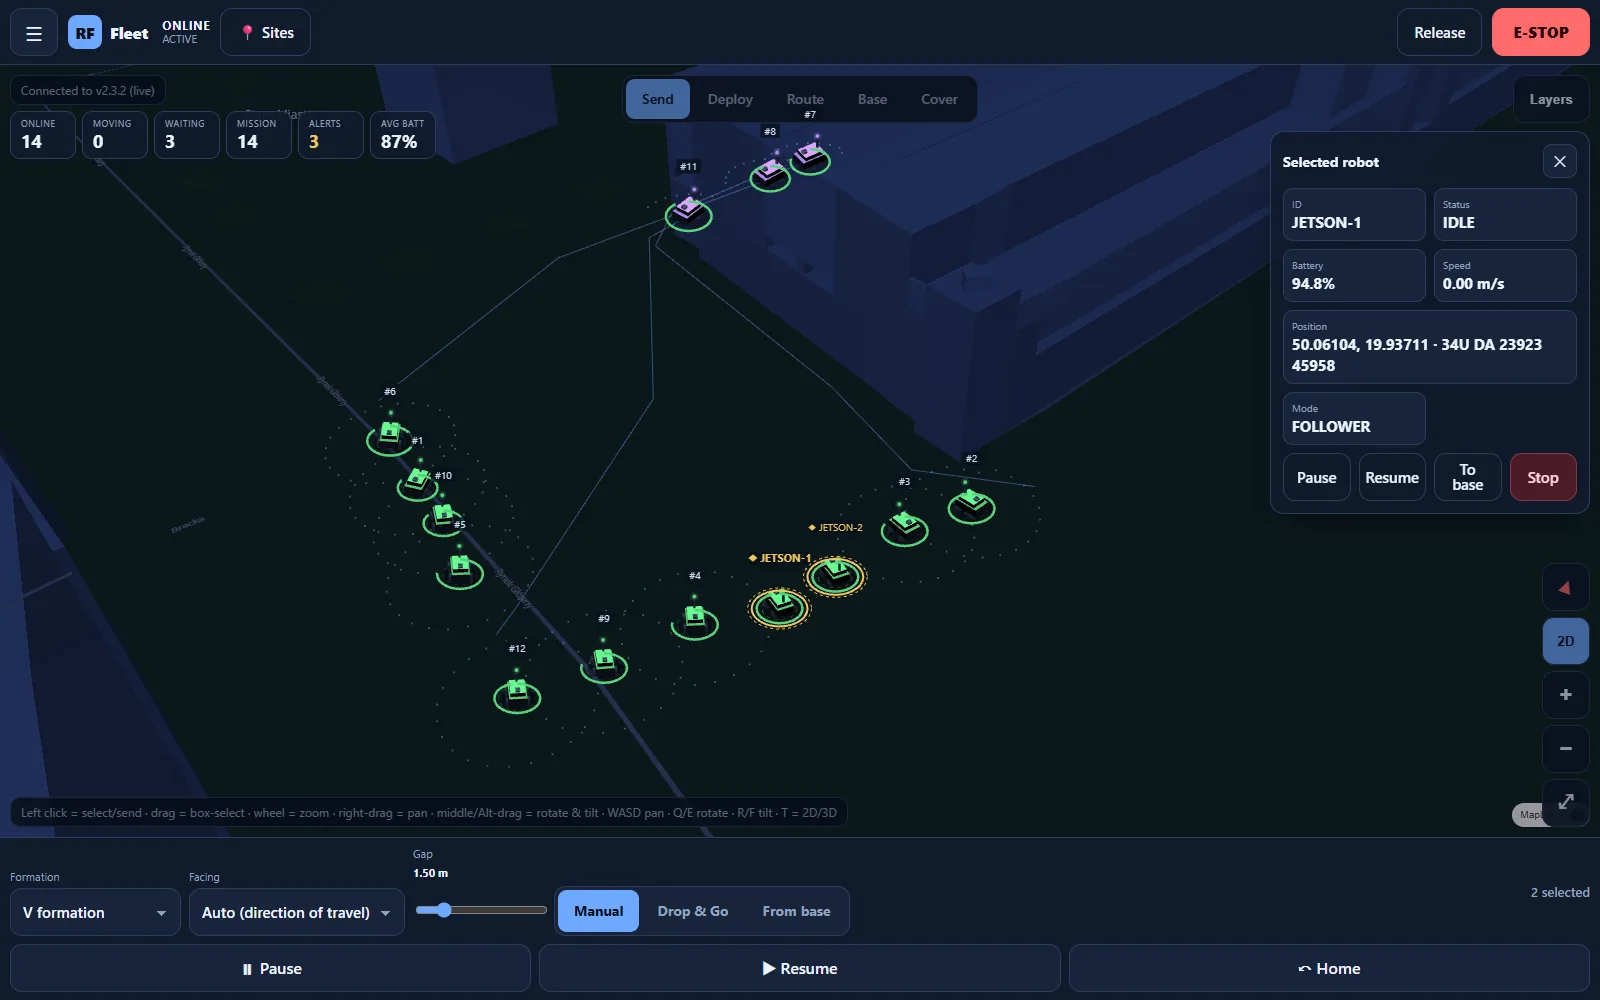
A plain-Python fleet server with a touch-first operator panel on ten real OpenStreetMap sites, driven from a browser over the LAN. On each robot an NVIDIA Jetson Nano runs the Robot Agent: it registers, streams telemetry, pulls its next waypoint, turns it into wheel speeds and stops the robot by itself if the server goes quiet.
What works, and what does not
- Robots register over HTTP, stream telemetry and pull their next waypoint
- Planning around obstacles, other robots, no-go and slow zones, with formations, routes and bases
- Ten real sites from OpenStreetMap, with 3D buildings, working offline
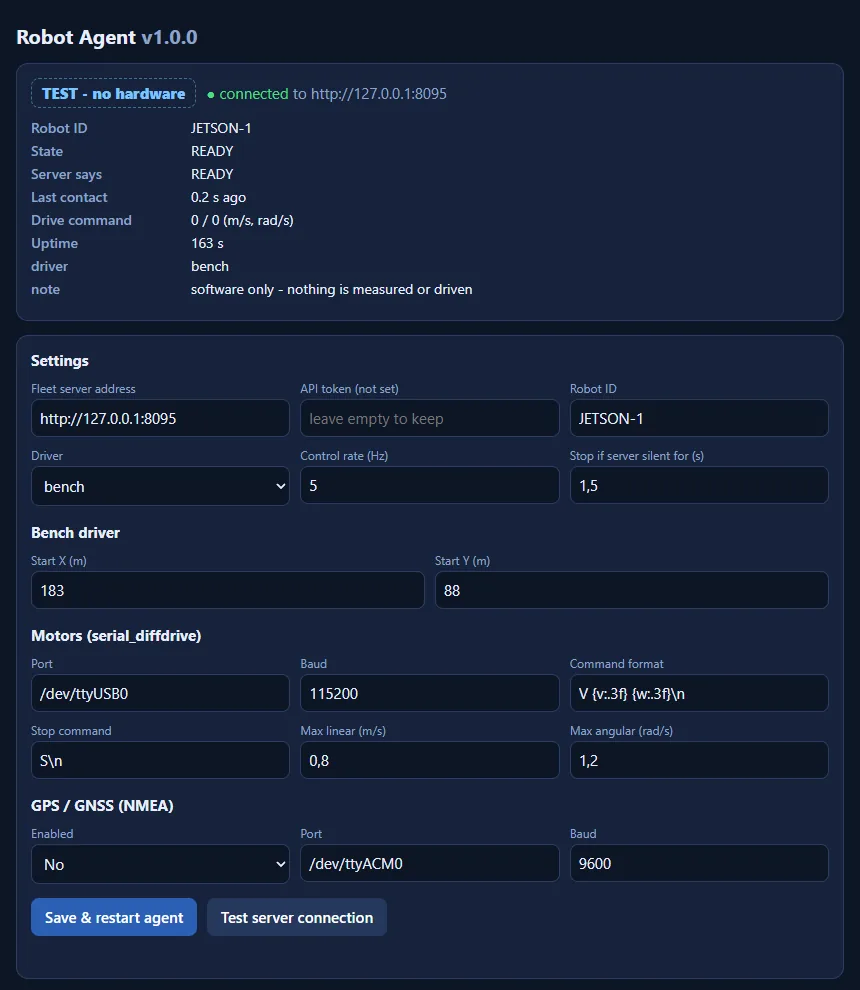
- Robot Agent for the Jetson Nano: system service, settings page, local stop when the server goes quiet
- WGS84, UTM and MGRS read-outs for field crews
- Touch-first operator panel, served from the box itself
- Alfa, the leader robot: an animated face, English voice commands with confirmation, and a strategist that proposes orders (off / advise / auto-safe / auto) with hard limits
- Alfa's eyes: camera face detection pauses robots moving near a person
- Audit trail and simulation speed-up up to ×20
- No motors or GPS receiver are connected yet: the serial motor driver and GPS reading are untested on hardware.
- The current agent (v1.0) still has to be installed and checked on the Jetson; an earlier version already connected from it.
- By design it does not do real-time motion safety: that belongs on the robot, close to its sensors, plus a hardware emergency stop.
What had to be got right
The server sends goals
Real-time motion safety belongs on the robot. A fleet server over a network sends destinations and constraints, never the last-metre decision.
No cloud, no packages
It runs on plain Python and its standard library, so a field box on a shelf keeps working with the internet unplugged.
Built for field crews
Touch-first panel and coordinate read-outs in the systems crews actually use (WGS84, UTM, MGRS).
The real build, recorded
Related projects
AMR Platform
An outdoor fleet platform with a safety state machine, traffic reservations and a costmap built from OpenStreetMap.
Open →AMR Flow Simulator
A browser tool that sizes a robot fleet for a warehouse before one is bought.
Open →Portable AI Workstation
A carry-anywhere enclosure around an NVIDIA Jetson module, with a touchscreen and the full Ubuntu desktop.
Open →Figures describe this project's own build at the time of writing, not a promise of anything else. All projects and statuses.